


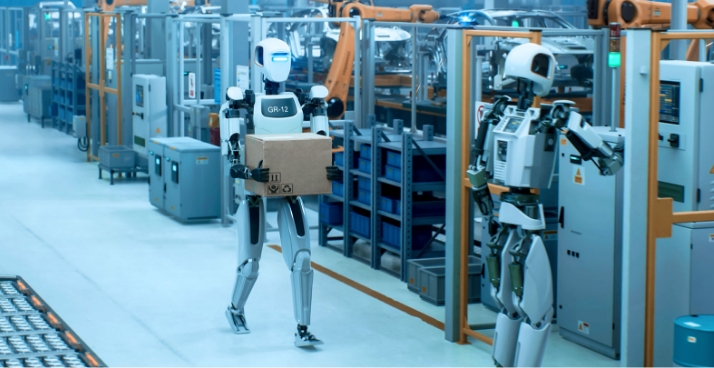
Gearboxes for Humanoid Robots: Compact Joint Solutions for Dynamic Environments
Humanoid robots operate in environments that are not entirely predictable. They must maintain a stable stance, handle varying loads, and continuously adapt their movements to people, tools, objects, and changing environmental conditions. This requires drive systems that combine precision, high power density, and intelligent functions for capturing gear, application, and status information within a compact footprint. Nabtesco has more than 40 years of experience in robotics and offers backlash-free shaft-type gearboxes, compact actuators, and digital shaft-type gearboxes for the joints of humanoid robots. These enable movements to be executed with precision and sensitivity.


Are you developing a humanoid robot and looking for suitable drive solutions for its joints?
Together, we’ll select the appropriate helical gearboxes and actuators and assist you with their design and integration.
Request a Consultation
What advantages do Nabtesco gearboxes offer in humanoid robots?
Nabtesco offers Strain wave gear drives and actuators for various joints in humanoid robots, particularly for the shoulders, elbows, hips, and legs. They enable compact designs, precise movements, and the integration of digital functions. Different levels of integration provide flexibility in development.
Your benefits:
- More stable standing and holding: Zero backlash, low transmission errors, and the holding torque help keep joints steady in position and reduce the need for control. This leads to lower energy consumption.
- Precise and sensitive movements: High rigidity and transmission accuracy support precise positioning and sensitive handling
- High power density in a compact footprint: High reduction ratios and compact designs enable joints with smaller motors
- Direct feedback from the drive: Space-saving integrated sensor technology provides status data to better monitor
loads and external influences
What advantages do Strain wave gearboxes offer over planetary gearboxes in humanoid robots?
Strain wave gearboxes are particularly well-suited for the joints of humanoid robots when high precision and compact designs are required. Approximately 40% of the teeth are in mesh at any given time. The distribution of the load across many teeth enables high transmissible torques, low transmission errors, and backlash-free power transmission. In planetary gearboxes, significantly fewer teeth are in mesh at any given time. They are generally more cost-effective but require additional design or control measures when high precision is required.
| Criterion | Strain wave gear | Planetary gearboxes |
|---|---|---|
| Backlash and Accuracy | Backlash-free with low transmission errors | Inherent backlash due to design (without preload) |
| Positioning and Holding | Back-torque helps maintain the joint position | Backlash results in greater control system effort |
| Reduction ratio and installation space | High reduction ratios enable compact joints and smaller motors | High reduction ratios often require multiple stages and additional installation space |
| Cost | Usually higher purchase price | Usually lower purchase price |
What challenges do wave gears address in humanoid joints?

Humanoid robots must actively stabilize their joint positions. Unlike humans, they cannot simply maintain positions by passing through a dead center and stopping precisely at the right point; instead, they must ensure the necessary stability through actuators and control systems. This continuous readjustment consumes energy and generates heat. Backlash-free shaft-type gearboxes limit gear-related deviations and, thanks to their back-torque, counteract external reverse rotational movements. This increases energy efficiency, enabling longer operating times with the same battery capacity.

Humanoid robots must be able to perform their movements reliably even under varying loads and external influences. To do so, they require a high degree of dexterity. The high rigidity and precision of the helical gears support precise manipulation and interaction with their environment.

In humanoid robots, gearboxes, motors, bearings, cabling, and sensors share a confined installation space. High reduction ratios and compact designs enable compact drive units with smaller motors, while hollow-shaft solutions allow for space-saving routing of cables and components. Compared to short-design shaft gearheads of the same size, Nabtesco short gearheads offer 20% more torque and a 40% longer service life. Our digital shaft gearheads integrate additional sensor and digital functions without requiring any extra space.
What added value does the digital wave gear offer?
Nabtesco’s digital bevel gear combines backlash-free gear technology with analytics and digital functions integrated in a space-saving design. This allows data such as position, torque, temperature, and vibration to be captured directly within the drive. Meta-data and analytical data are also available. This enables the robot to better account for loads and external influences and to execute its movements in a manner more appropriate to the situation.
| Feature | Benefits for Humanoid Robots |
|---|---|
| Torque and Position | Precise measurement of loads and joint positions |
| Temperature and vibration | Early indications of abnormal operating behavior |
| Space-saving sensor technology | Direct data acquisition within the transmission without requiring additional installation space |
| Real-time transmission data | Up-to-date data foundation for control and condition monitoring |
| Modular functions | Adaptation to the specific application |
What are the advantages of Nabtesco actuators?
Nabtesco actuators combine a shaft gearbox, motor, and other components into a single compact unit. This reduces design complexity and facilitates integration into humanoid joints. Functions and interfaces can be customized for each specific application. An optional hollow shaft enables space-saving cable routing.
Find Actuators
Typical Applications of Humanoid Robots
Humanoid robots perform tasks in work environments designed for humans. These include, for example, handling and assembly tasks in industry, as well as support activities in the service or care sectors.
To do so, they must:
- work in environments designed for humans
- respond to unexpected situations
- handle changing tasks without fixed procedures

Why Choose Nabtesco as a Partner for Humanoid Robotics?
Nabtesco combines more than 40 years of experience in robotics with development and mass-production expertise from the automotive industry. Its IATF-certified production of Strain wave gearboxes in Germany ensures high quality standards and reliable mass production. Developers and manufacturers of humanoid robots benefit from comprehensive support in the design, integration, and scaling of drive solutions.
An Overview of Robotics Solutions
Our Product Solutions for Humanoid Robots

Hollow-Shaft
Strain Wave Gear Kit
The simplest version of the Strain wave gear

Shaft Gear Kit
with Solid and Hollow Shafts
Including Output Bearing Assembly

Plug & Play
Shaft Gearbox with Solid and Hollow Shafts
Including Input and Output Bearings + Sealing System

Shaft Gear Kit
with Solid and Hollow Shafts
Including Smart Sensors and Artificial Intelligence

Plug-and-Play
Shaft Drive Systems with Solid and Hollow Shafts
Complete Systems for Your Automation Needs

Strain Wave Gear Kit
with Solid and Hollow Shafts
120% Torque & 140% Service Life with the Same Size
FAQ: Frequently Asked Questions About Gearboxes for Humanoid Robots
A humanoid robot is a mechatronic system modeled after human capabilities and abilities. It usually has a torso and arms, and often a head as well. Locomotion can be achieved through legs, wheels, or other mobile platforms. Humanoid robots are designed to perform tasks in environments originally intended for humans.
Gearboxes for humanoid robots must support precise movements and the stable positioning of joints within a confined space. This requires high power density, low transmission errors, and a back-torque that counteracts external forces. As a result, the control system must compensate for fewer gear-related deviations.
Strain wave gears operate without backlash and enable high reduction ratios in a compact design. Planetary gears are generally more cost-effective; however, due to their design, they exhibit backlash when not preloaded and often require multiple stages to achieve high reduction ratios.
A digital shaft-type gearbox captures operating data such as torque, position, or temperature directly within the drive. This data supports control and condition monitoring. In Nabtesco’s digital shaft-type gearbox, the sensor technology is integrated without requiring additional installation space
and does not require any additional installation space. Analytics and intelligence within the gearbox also enable new functions—such as Gear Boosting, in which torque limits are dynamically adjusted to the current operating conditions. This allows the gearbox to be operated as needed within the currently permissible load limits.
Strain wave gear drives are particularly well-suited for joints such as the shoulders and elbows, where high positioning accuracy and compact designs are crucial. Depending on the load, they can also be used in hip or leg joints.
The counter-torque counteracts external forces that attempt to displace a joint from its position. Together with backlash and minimal transmission errors, it can help keep joints stable and reduce the amount of control required.
